Control Systems
Instructions:
- The marks are indicated in the right-hand margin.
- There are NINE questions in this paper.
- Attempt FIVE questions in all.
- Question No. 1 is compulsory.
A control system with feedback generally has
In signal flow graph analysis, a loop in contact with another loop is called
For a second-order underdamped system, increasing damping ratio decreases
The number of branches in a root locus equals the number of
Breakaway points in root locus occur where
A Type-1 system has zero steady-state error for
The slope of magnitude plot for a single pole in Bode plot is
Phase margin is the additional phase lag required to make the system
Root-locus based controller design mainly involves adjustment of
State-space analysis is particularly useful for
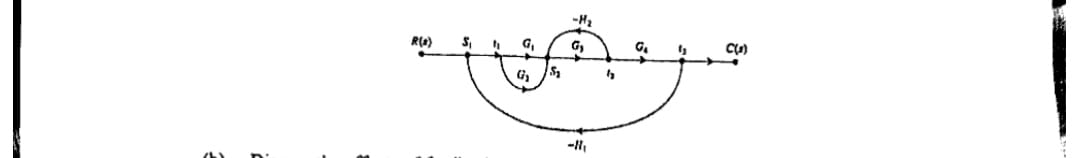
Explain signal flow graphs and derive Mason’s Gain Formula. Determine the transfer function (C(s)/R(s)) for given signal flow graph.
Discuss the effects of feedback on stability, sensitivity, bandwidth, and steady-state error of a control system.
A unity feedback system has:
G(S) = 25/[S(S+5)]
Determine: (i) Damping ratio (ii) Natural frequency (iii) Peak overshoot (iv) Settling time.Derive expressions for rise time and maximum overshoot for a standard second-order system.
Using the Routh–Hurwitz criterion, determine the stability of the system whose characteristic equation is: S4 + 2S3 + S2 + 2S + 1 = 0.
Sketch the root locus for:
G(S)H(S) = K/[S(S+2)(S+4)]
Determine the breakaway points and imaginary-axis crossings.
Explain the effect of adding poles and zeros on the transient response and stability of a control system.
State and explain the Nyquist stability criterion. Also draw the Nyquist Plots for:
G(S)H(S) = 3/[(S+2)(S−1)]
Discuss gain margin and phase margin and explain their significance in relative stability analysis.
Explain lag compensation and discuss its effect on steady-state accuracy and bandwidth.
Discuss the concept of robustness in control systems and explain how controller design improves robustness.
Explain the concepts of state variables, state equations, and state-space representation with suitable example.
Discuss the stability of discrete-time systems and explain the role of eigenvalues in determining system stability.
Test the controllability and observability of the system:
A = [0 1; −2 −3], B = [0; 1], C = [1 0]
Routh–Hurwitz stability criterion and its significance
Gain margin and phase margin in frequency response analysis
Initial value theorem and final value theorem
closed-loop control systems